ompl::app::FCLStateValidityChecker< T > Class Template Reference
Wrapper for FCL collision and distance checking. More...
#include <omplapp/geometry/detail/FCLStateValidityChecker.h>
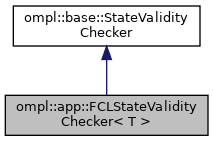
Inheritance diagram for ompl::app::FCLStateValidityChecker< T >:
Public Member Functions | |
| FCLStateValidityChecker (const ob::SpaceInformationPtr &si, const GeometrySpecification &geom, const GeometricStateExtractor &se, bool selfCollision) | |
| bool | isValid (const ob::State *state) const override |
| Checks whether the given robot state collides with the environment or itself. | |
| double | clearance (const ob::State *state) const override |
| Returns the minimum distance from the given robot state and the environment. | |
| const FCLMethodWrapperPtr & | getFCLWrapper () const |
 Public Member Functions inherited from ompl::base::StateValidityChecker | |
| StateValidityChecker (SpaceInformation *si) | |
| Constructor. | |
| StateValidityChecker (const SpaceInformationPtr &si) | |
| Constructor. | |
| virtual bool | isValid (const State *state, double &dist) const |
| Return true if the state state is valid. In addition, set dist to the distance to the nearest invalid state. | |
| virtual bool | isValid (const State *state, double &dist, State *validState, bool &validStateAvailable) const |
| Return true if the state state is valid. In addition, set dist to the distance to the nearest invalid state (using clearance()). If a direction that moves state away from being invalid is available, a valid state in that direction is also set (validState). validStateAvailable is set to true if validState is updated. | |
| virtual double | clearance (const State *state, State *, bool &validStateAvailable) const |
| Report the distance to the nearest invalid state when starting from state, and if possible, also specify a valid state validState in the direction that moves away from the colliding state. The validStateAvailable flag is set to true if validState is updated. | |
| const StateValidityCheckerSpecs & | getSpecs () const |
| Return the specifications (capabilities of this state validity checker) | |
| virtual bool | operator== (const StateValidityChecker &) const |
| Checks for equivalence between two Statevaliditycheckers. | |
| bool | operator!= (const StateValidityChecker &rhs) const |
Protected Attributes | |
| OMPL_FCL_StateType< T > | stateConvertor_ |
| Object to convert a configuration of the robot to a type desirable for FCL. | |
| FCLMethodWrapperPtr | fclWrapper_ |
| Wrapper for FCL collision and distance methods. | |
| Protected Attributes inherited from ompl::base::StateValidityChecker | |
| SpaceInformation * | si_ |
| The instance of space information this state validity checker operates on. | |
| StateValidityCheckerSpecs | specs_ |
| The specifications of the state validity checker (its capabilities) | |
Detailed Description
template<MotionModel T>
class ompl::app::FCLStateValidityChecker< T >
Wrapper for FCL collision and distance checking.
Definition at line 98 of file FCLStateValidityChecker.h.
The documentation for this class was generated from the following file:
- omplapp/geometry/detail/FCLStateValidityChecker.h